· Agricultural robotics
In developmentHarvest receiving bin
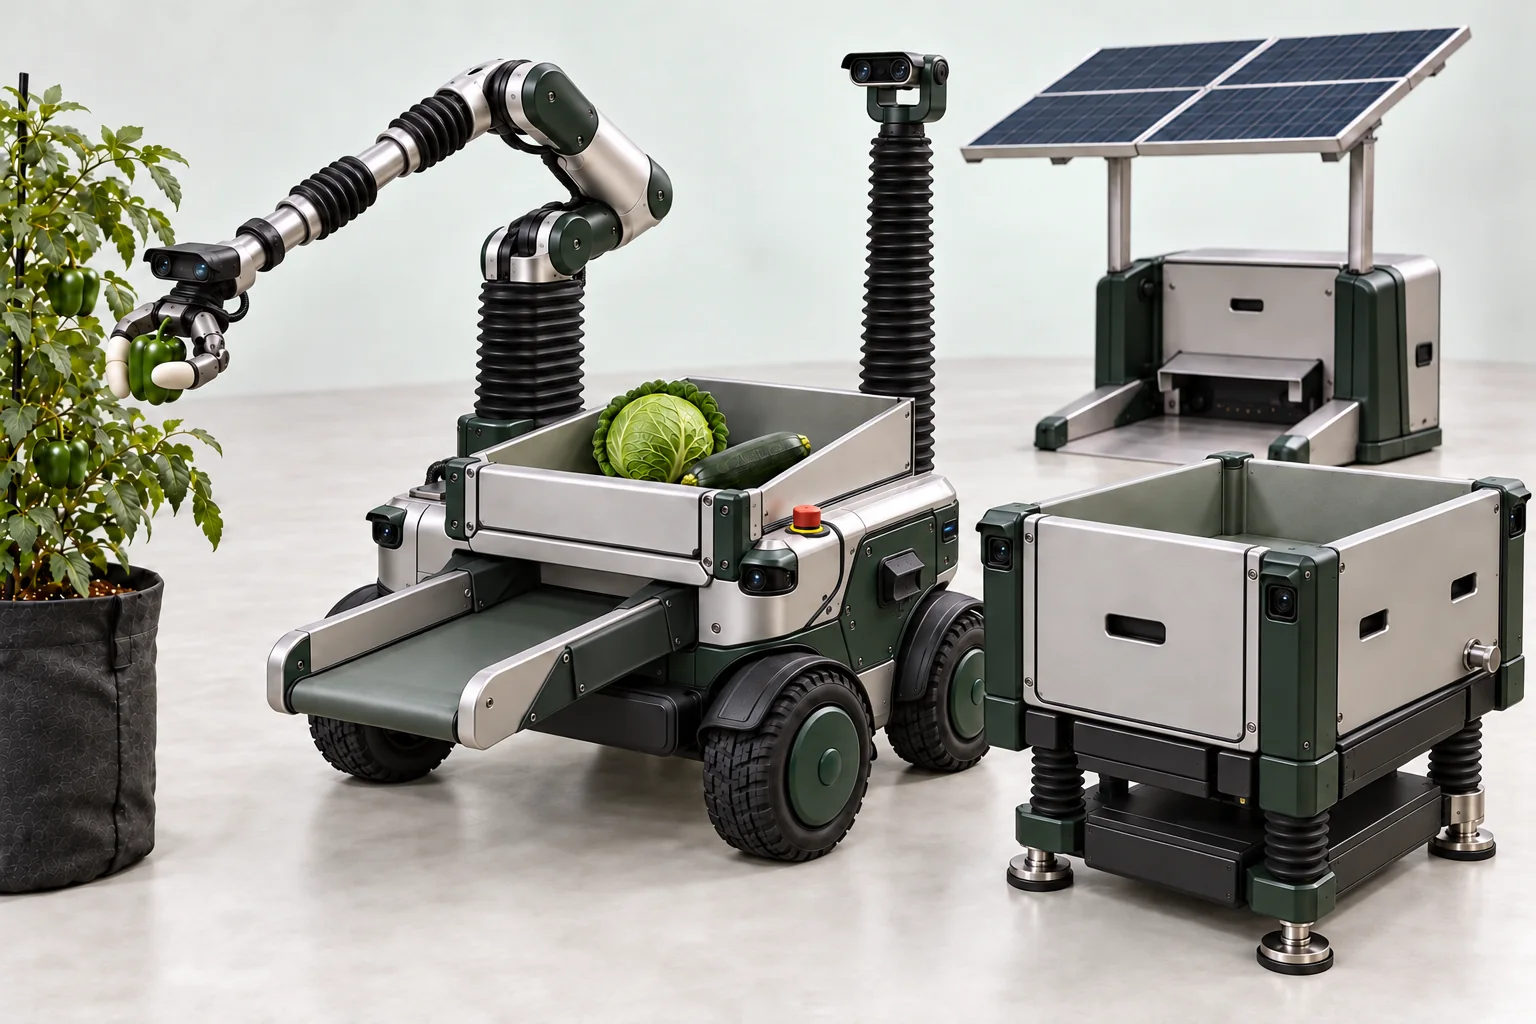
The large bin collects vegetables from the robot’s smaller onboard tray. In the current design, the bin sits on a stationary platform and can be removed so the crew can take the harvest away.
Electric actuation · Form study
A robot. A harvest station. A solar dock. One connected system in development.
How it works
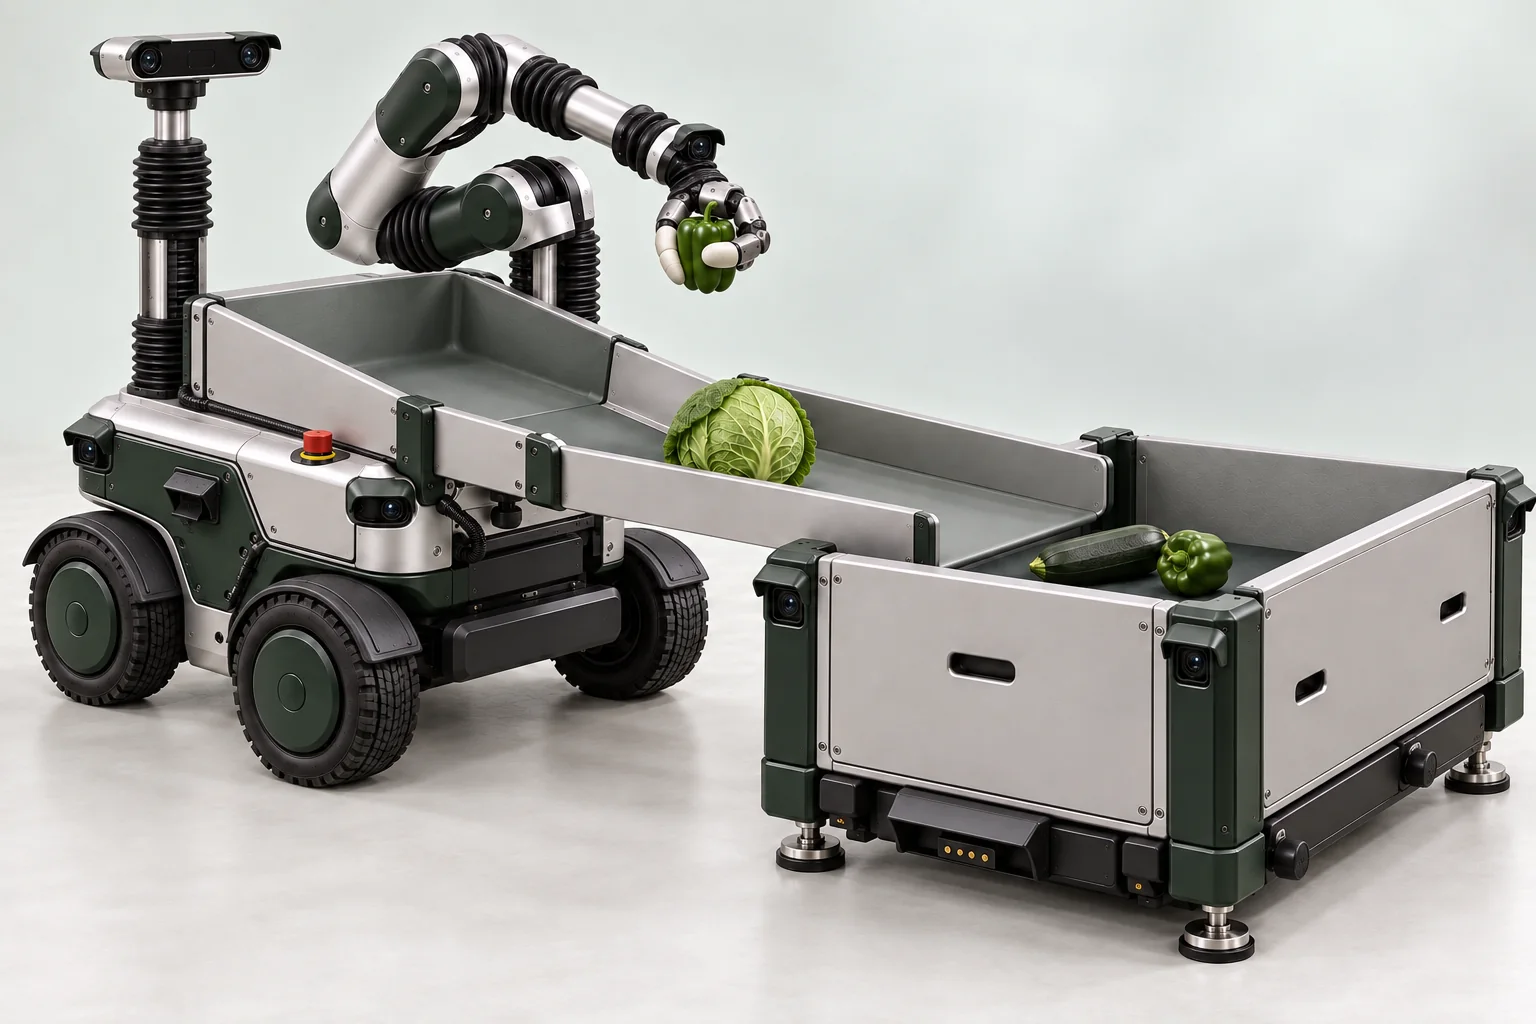
The robot would bring its belt over the receiving bin. Setting the bin to the right height would keep the drop short and help protect delicate crops.
We are exploring a second version that could follow the Farm Bot on powered wheels. Cameras around the bin would watch the route, and wheel encoders would track its movement. A sealed controller underneath would connect the drives and battery to the sensors.
The mobile bin would stop beside the harvester before transfer. It would also stop if it lost track of the robot or an obstacle blocked its path.
What we need to test
- For the stationary bin, check stability, working height, removal for cleaning and the weight of an actual harvest.
- The mobile option needs its own price and trials. Test tracking, braking with a full load and safe unloading on uneven ground.