· Agricultural robotics
In development← Farm Bot
The hand and its two camera views
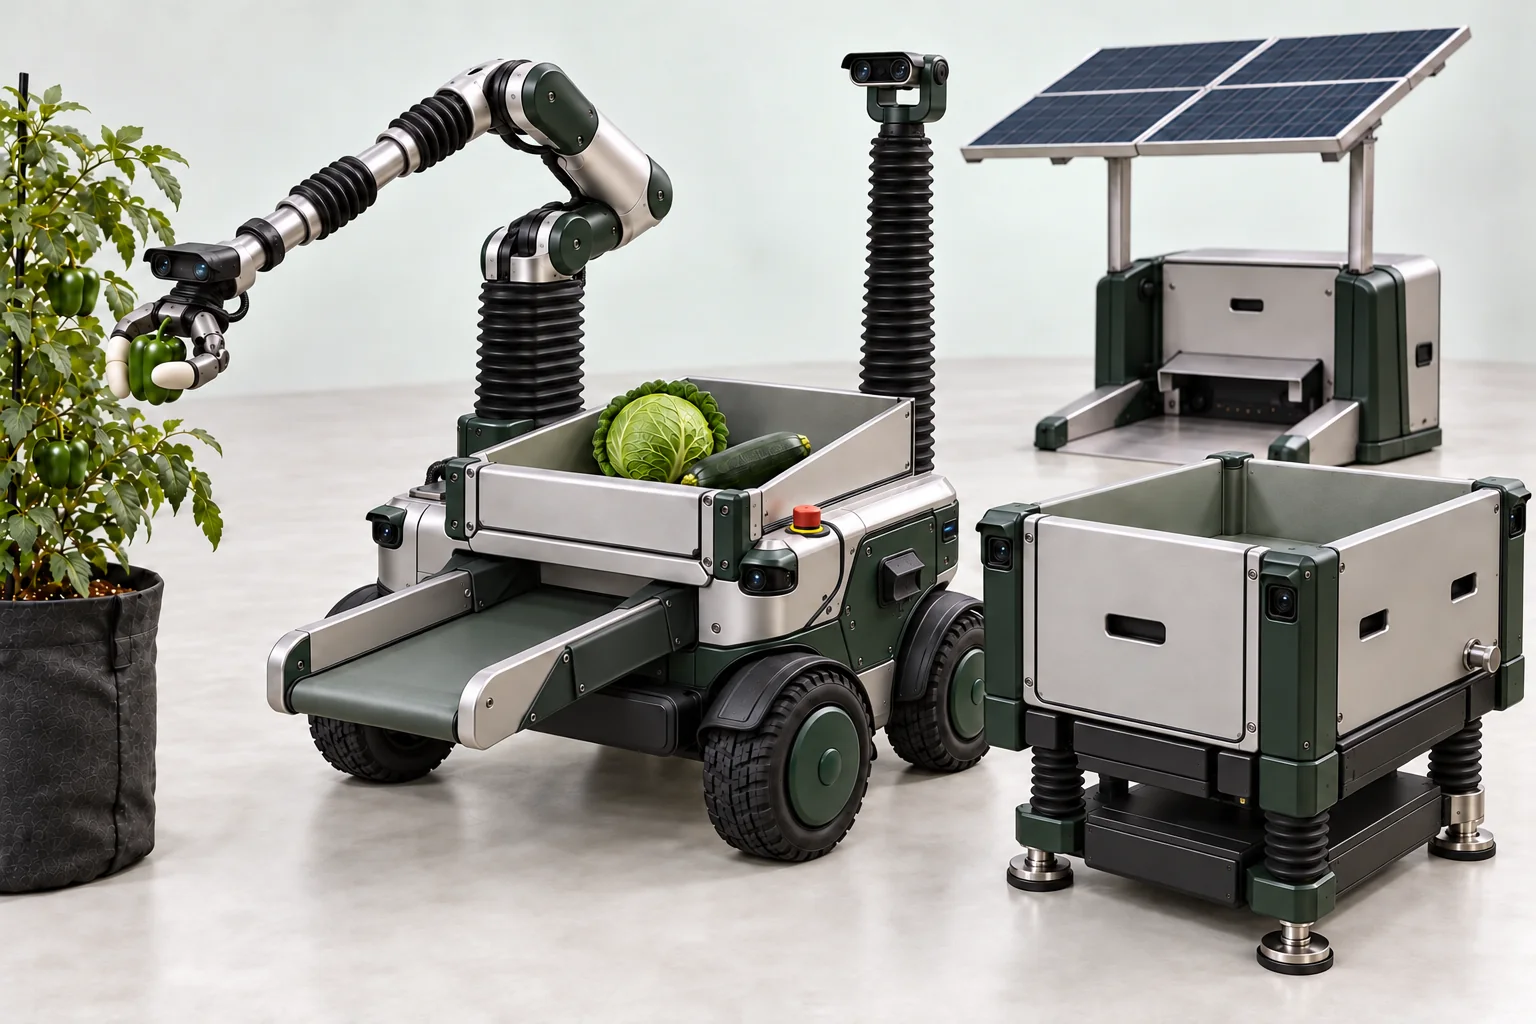
The proposed camera above the hand would guide the fingers through the last few centimetres of a pick. A separate camera on a raised rear mast would look over the arm to help the robot spot obstacles.
Electric actuation · Form study
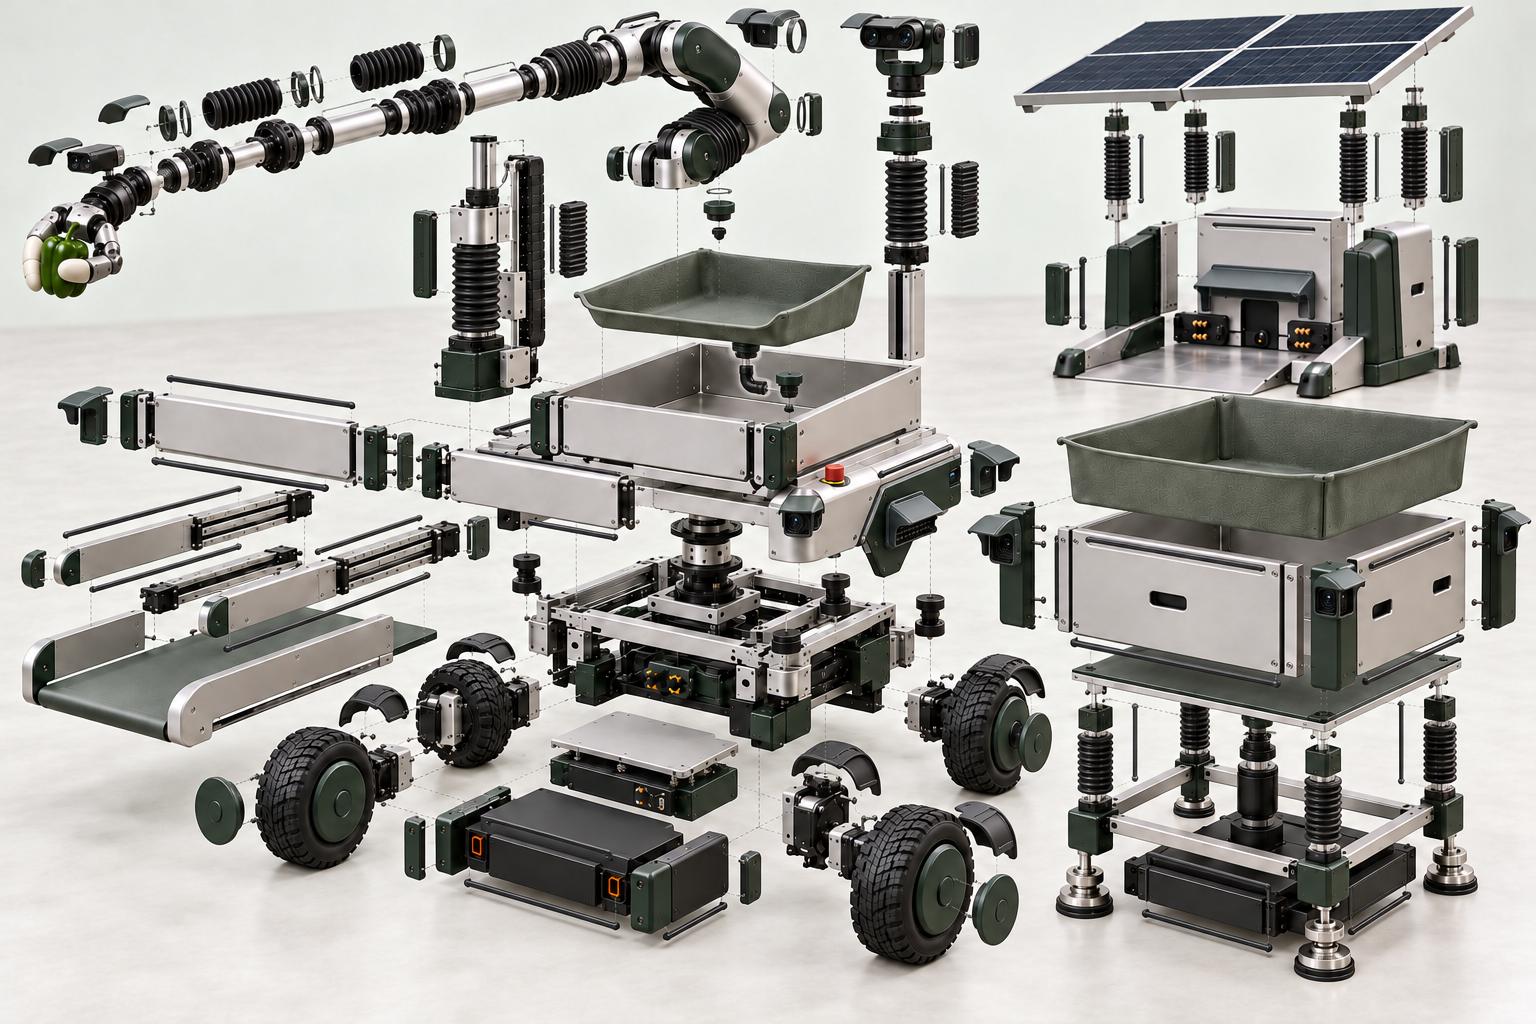
A robot. A harvest station. A solar dock. One connected system in development.
How it works
The wrist camera moves with the hand. From above the grip, it could keep both the fingertips and the target in view as the hand approaches, closes and releases.
The rear camera has a different job. Its viewpoint would stay independent of the wrist so the robot can watch its surroundings while the arm reaches into foliage.
What we need to test
- Measure placement error, repeatability and bruising on real crops, including when leaves partly hide the target.
- Move the arm through its full range and check whether it blocks the rear camera. Test stopping distance when a person or an object enters the route.