· Agricultural robotics
In developmentFarm Bot harvesting robot
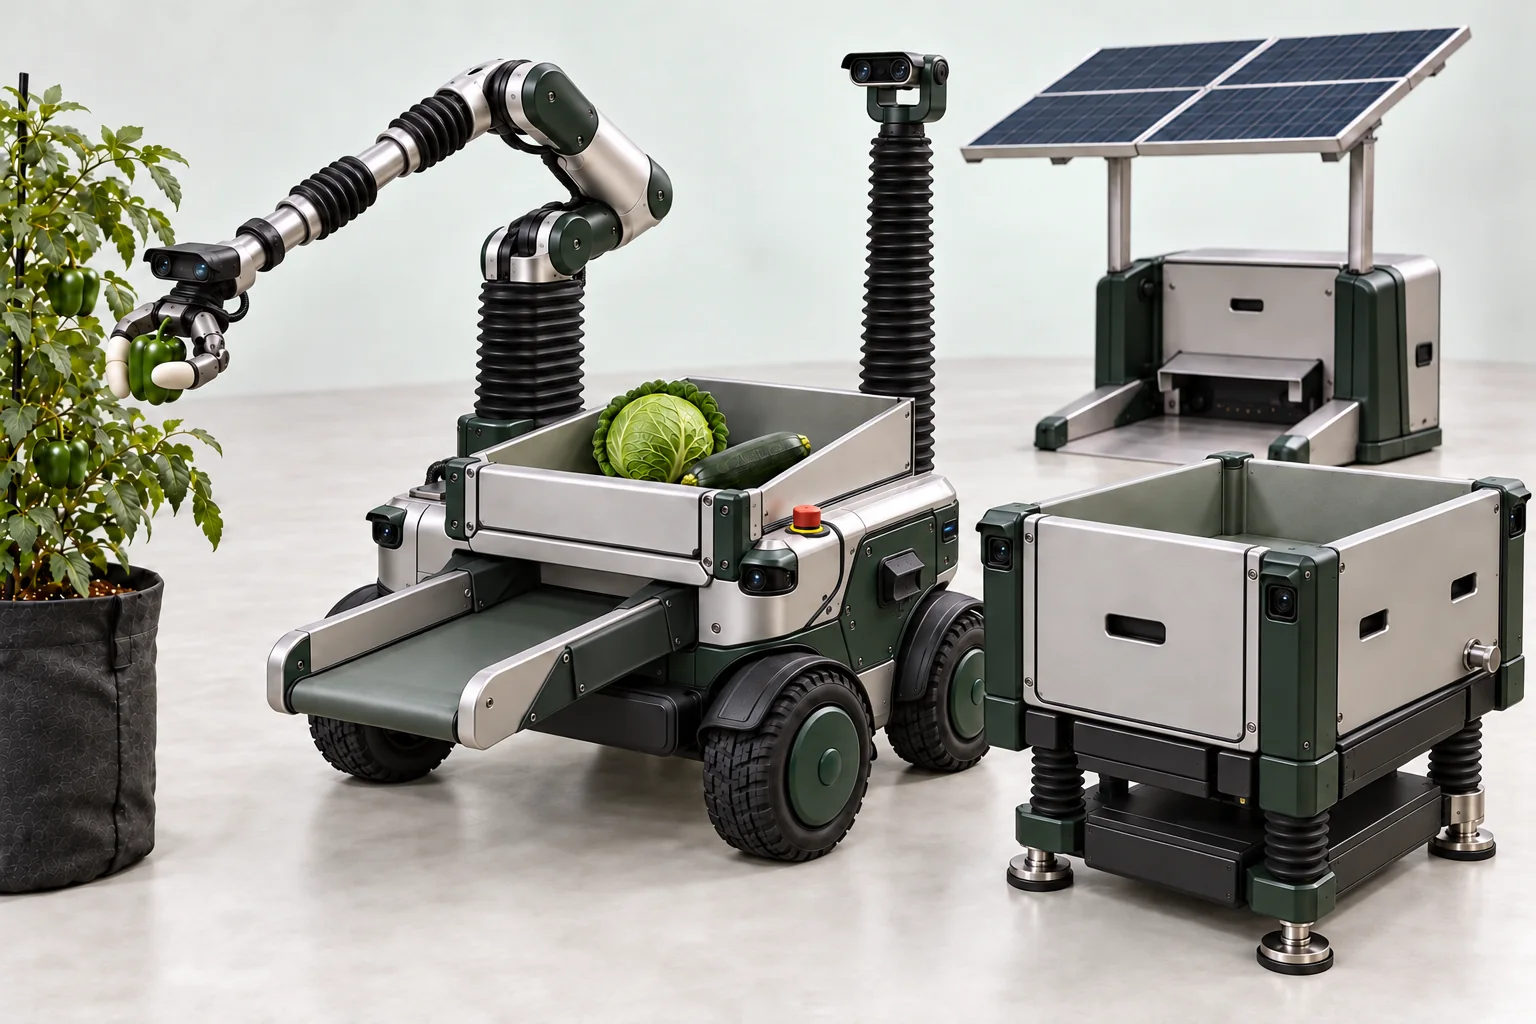
The Farm Bot is a four-wheel robot designed to bring a camera and a gentle grip to a crop, pick it and carry it to the receiving bin. It is the physical platform we envision for our crop models.
Electric actuation · Form study
A robot. A harvest station. A solar dock. One connected system in development.
How it works
The base would move beside a growing bed. A vertical lift and extending arm would bring the hand within reach while the farm team sets the picking criteria.
The hand would place each vegetable in the tray. The tray stays on the robot throughout the round, including when its belt unloads the vegetables.
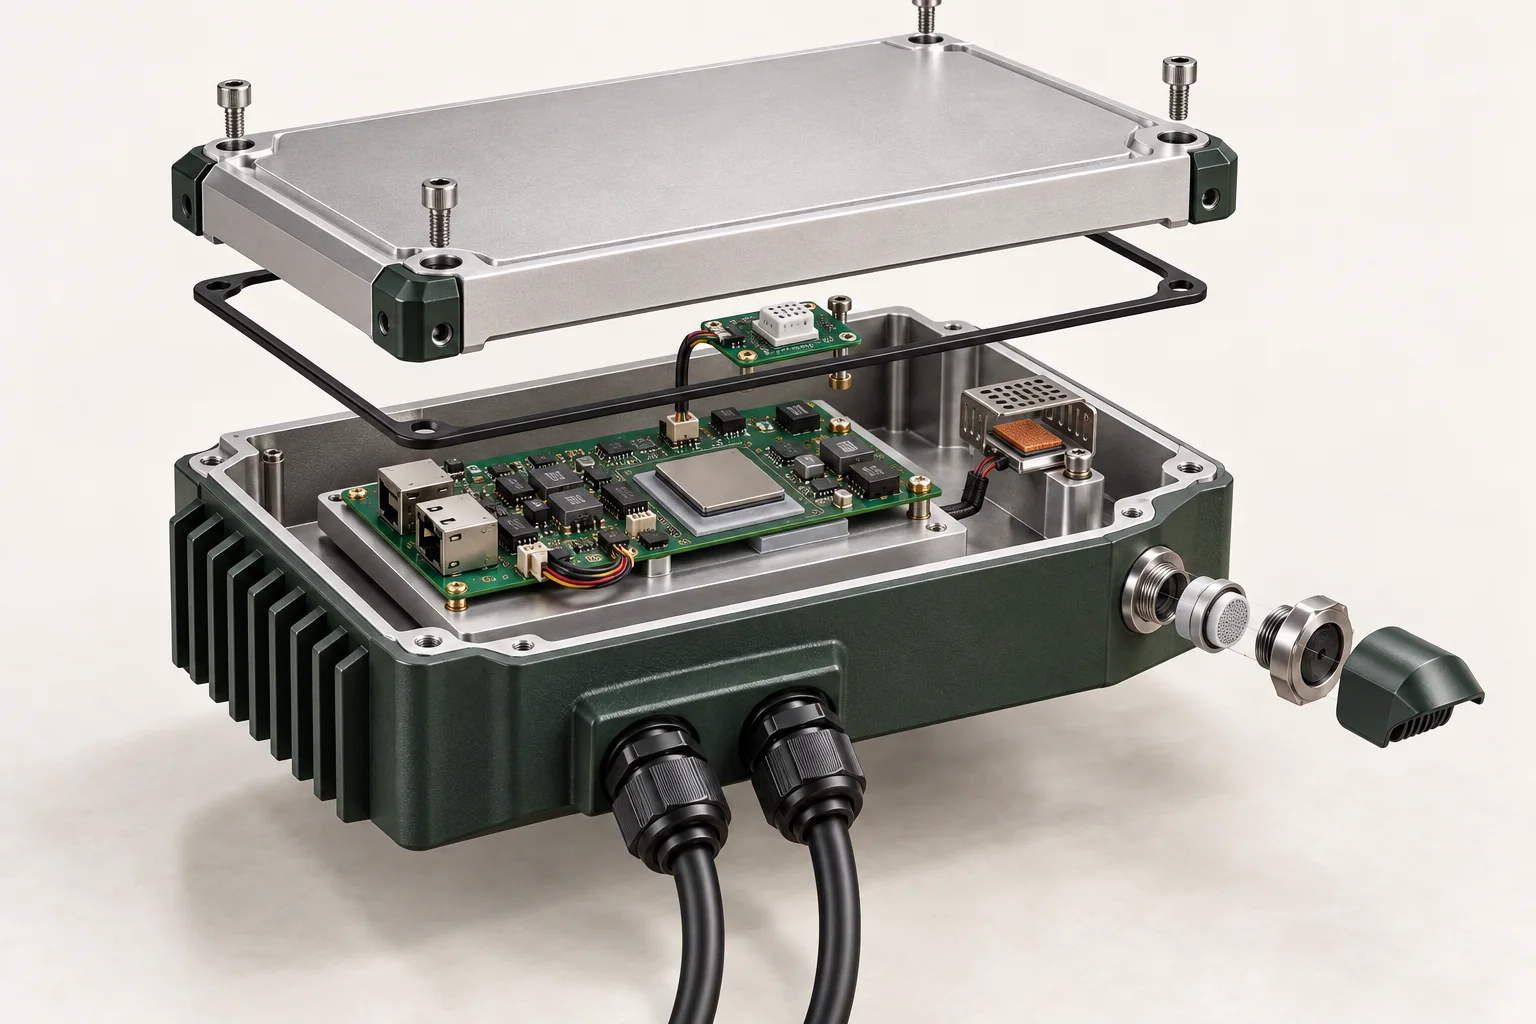
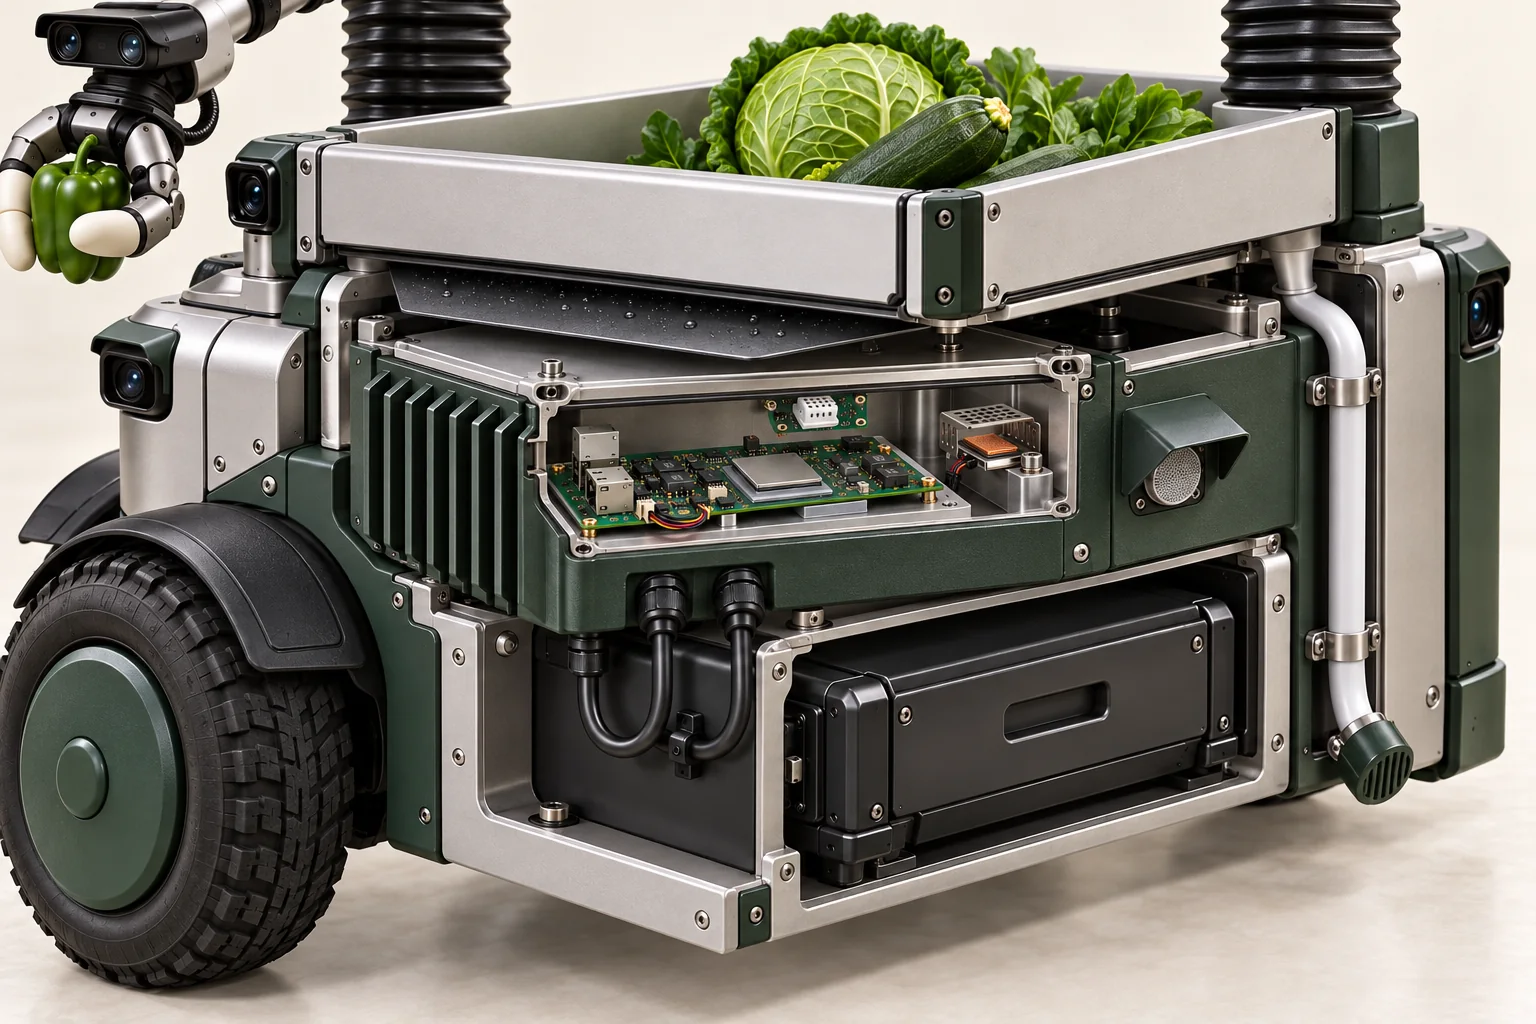
The cutaway view shows the planned location of the electronics beneath the tray. The separate enclosure view shows how a technician could reach those components.
What we need to test
- Compare the robot’s picks with the grower’s decisions on the same crop. Count missed ripe vegetables and record damage as well as the weight the crew can sell.
- Measure how often the crew intervenes, how much time the round takes and how the base and arm behave on the farm’s actual terrain.
Inside the electronics enclosure
The concept shows a circuit board inside a finned metal case. Cable entries run through the side, and the lid lifts away for access. On the assembled robot, this enclosure sits beneath the harvest tray.