· Agricultural robotics
In developmentFarm Bot specifications
These are features of the R9 engineering design. Performance figures will come from physical tests.
Electric actuation · Form study
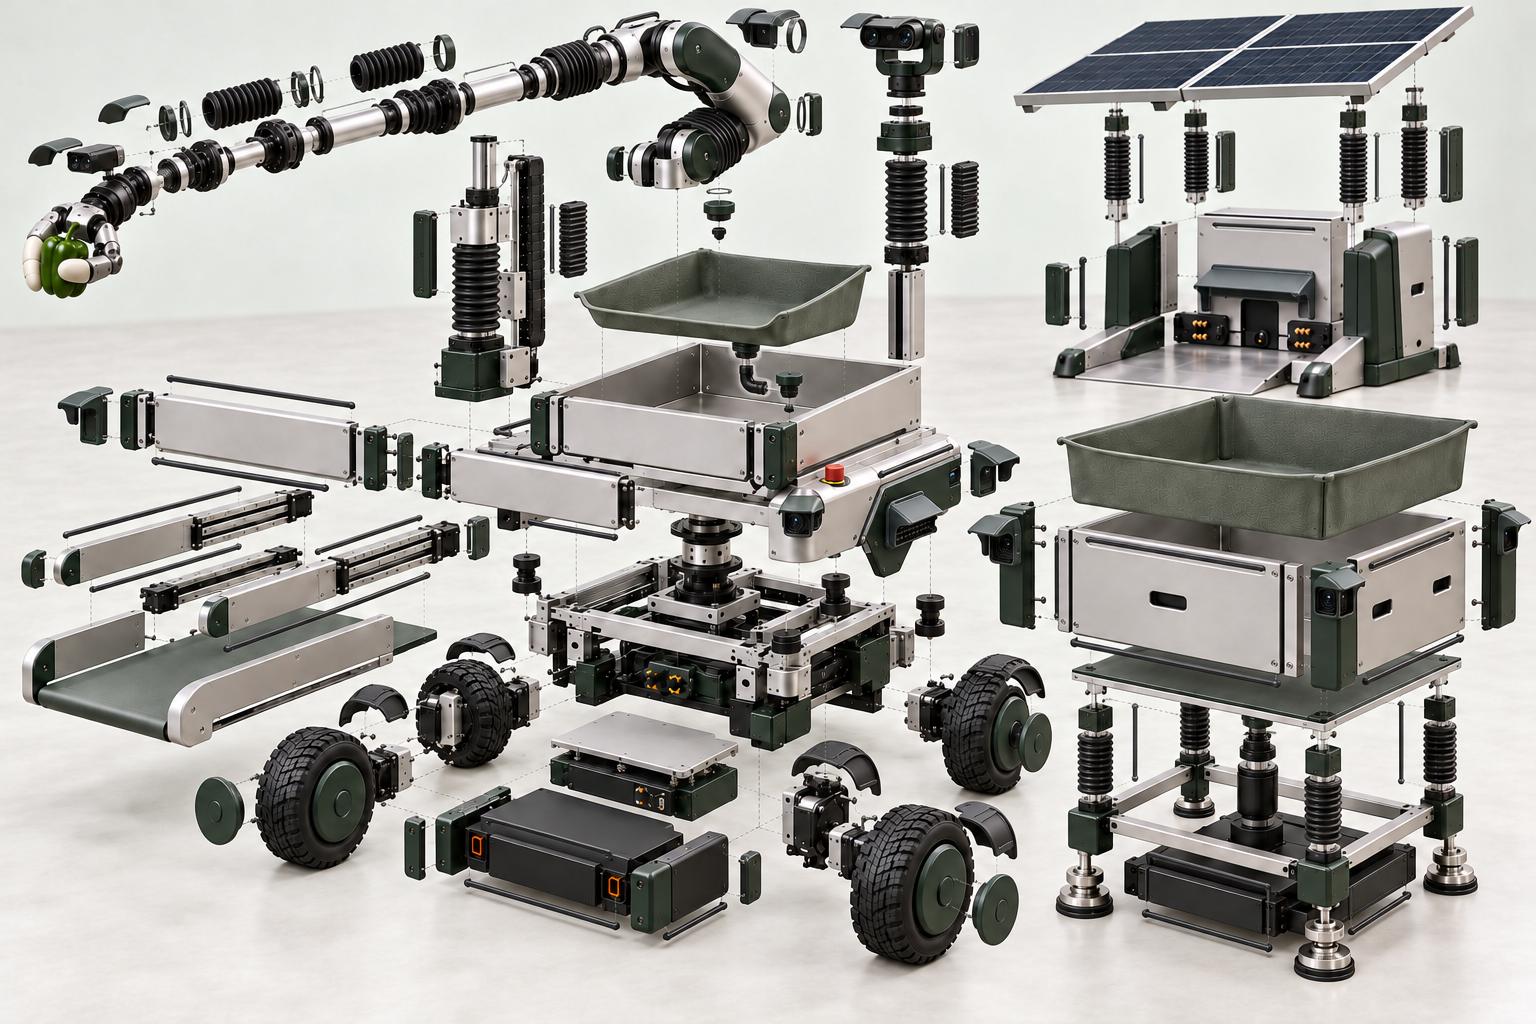
A robot. A harvest station. A solar dock. One connected system in development.
Specifications
Movement and reach
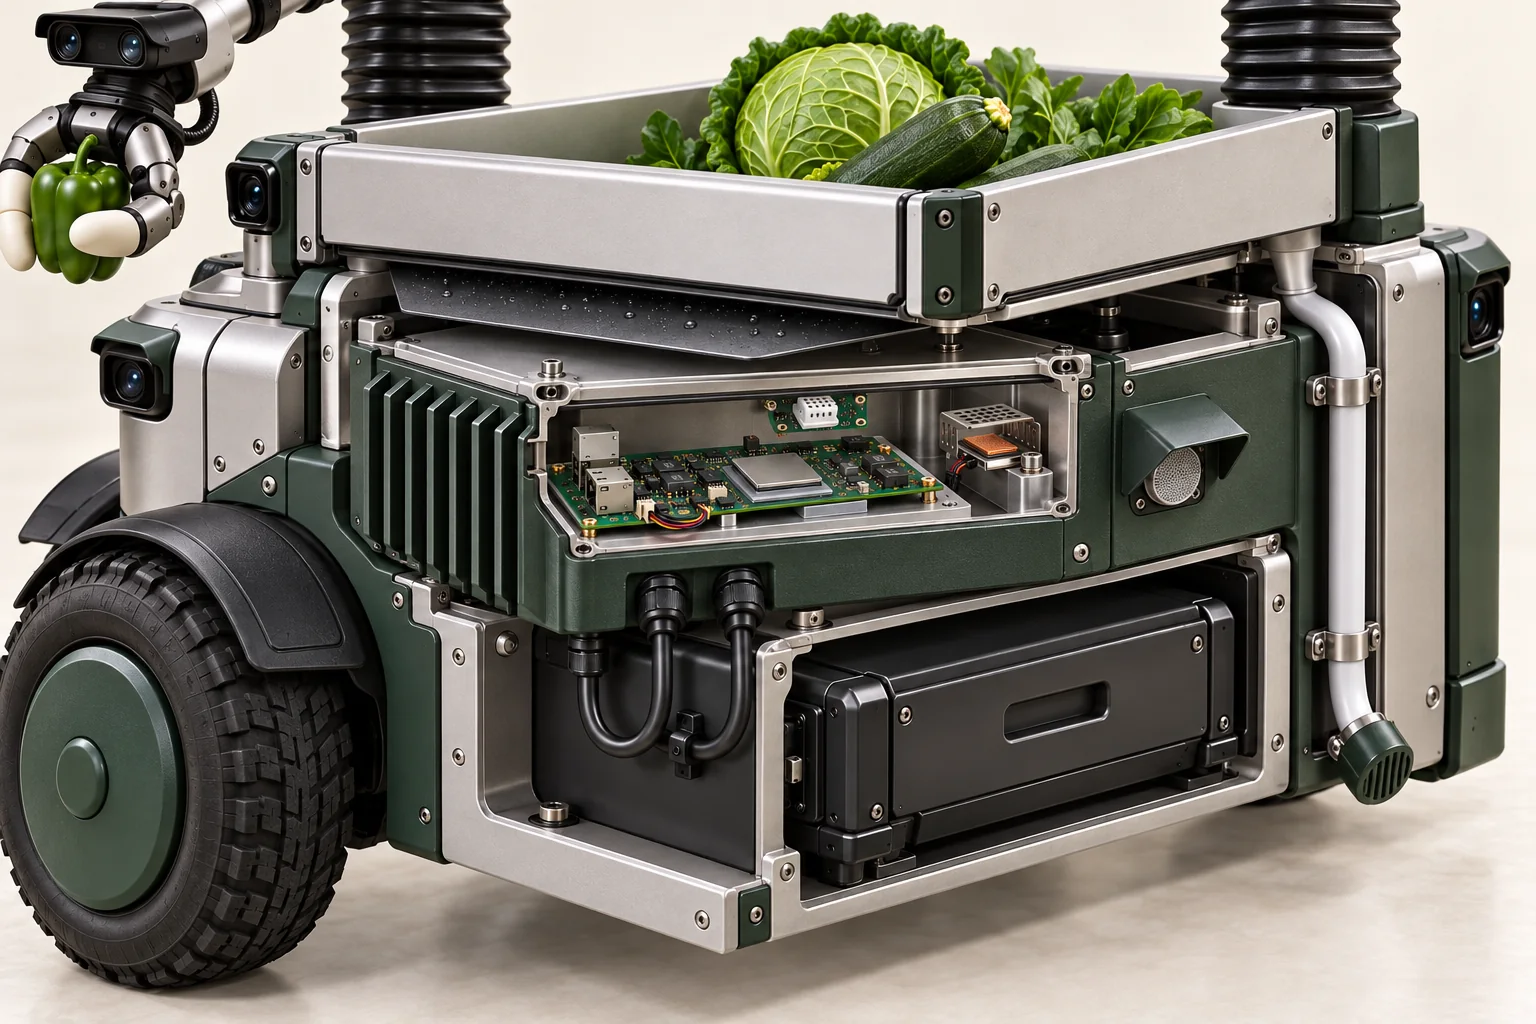
Four-wheel mobile base, vertical lift, extending articulated arm and camera-equipped wrist. Reach, clearance and safe operating limits must be checked on the assembled machine.
Two views of the crop and its surroundings
We are aiming for surgical precision when positioning the hand near a crop. The proposed camera on top of the hand would guide the fingertips. A separate camera on a rear mast would give a wider view as the robot moves. Tests must measure positioning error, repeatability and crop damage.
Harvest handling
The design includes a collection tray and a separate receiving station. Five kilograms is a design load to test. Actual payload, picking rate and crop compatibility are still being evaluated.
Power and return
The robot would dock automatically to charge its onboard battery. The station would store solar energy in its own battery. Docking reliability, charging time, runtime and outdoor protection still require physical tests.
Planning for assembly
We expect Shenzhen to be the likely location for assembly. The CAD model and supporting engineering files exist. Factory arrangements and commercial production still need to be confirmed.
What the images show
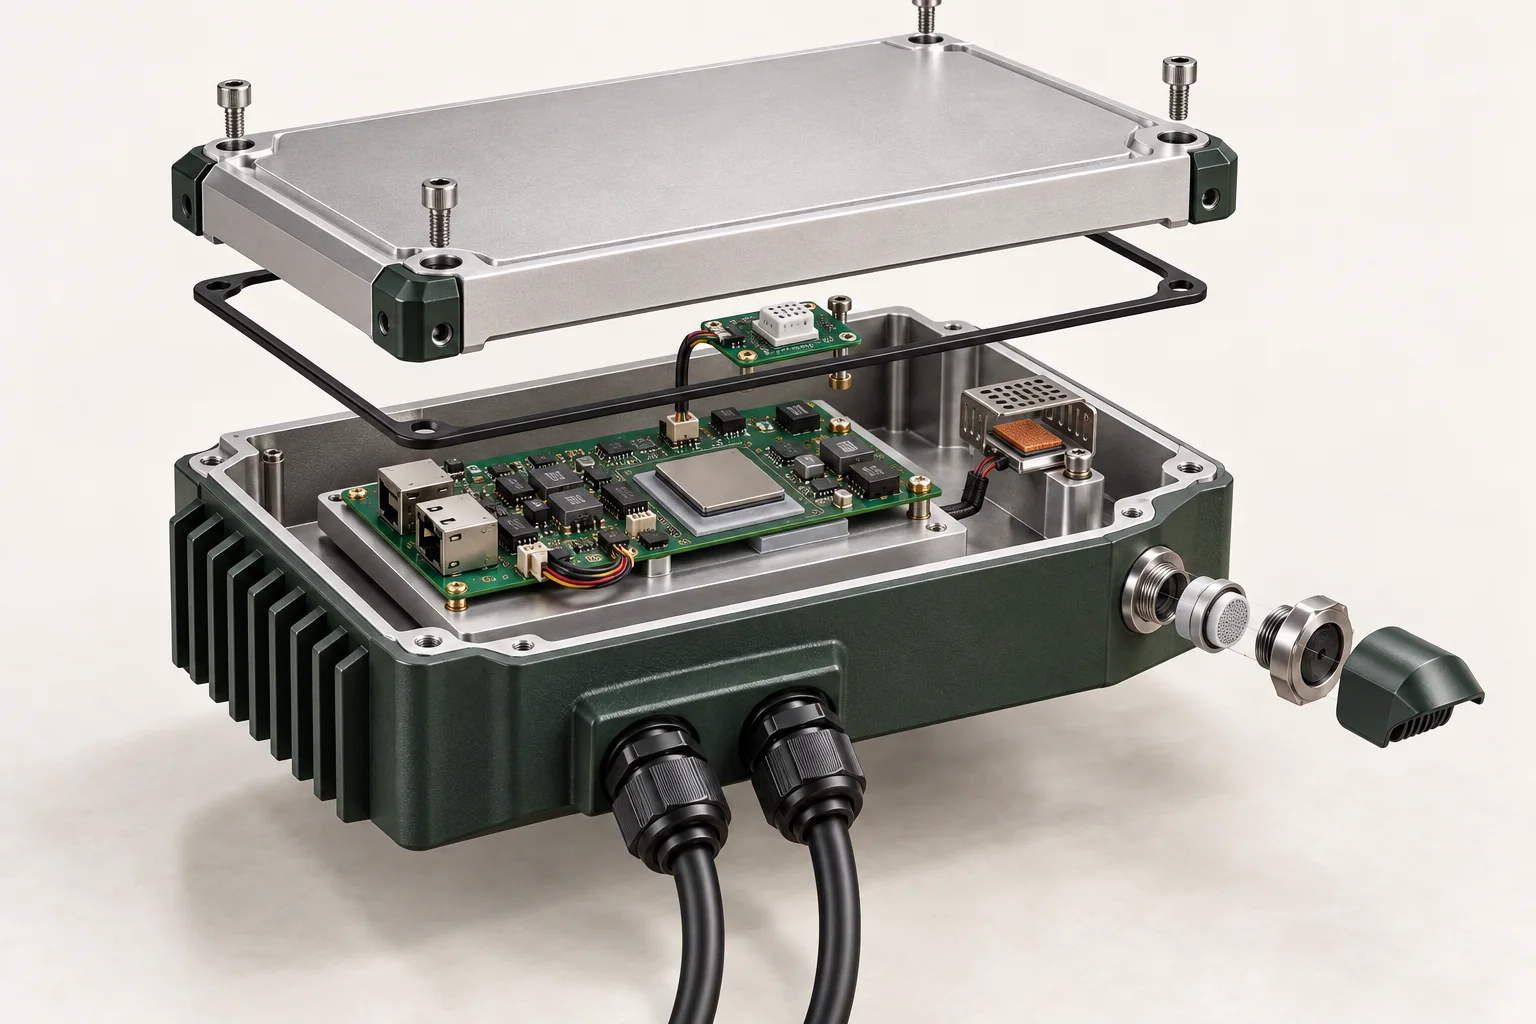
The illustrations show how the team envisions the robot. The R9 CAD model is a separate engineering reference. We still need to build the robot and test it on a farm.
Design views