· Agricultural robotics
In development← Farm Bot
Powered harvest belt
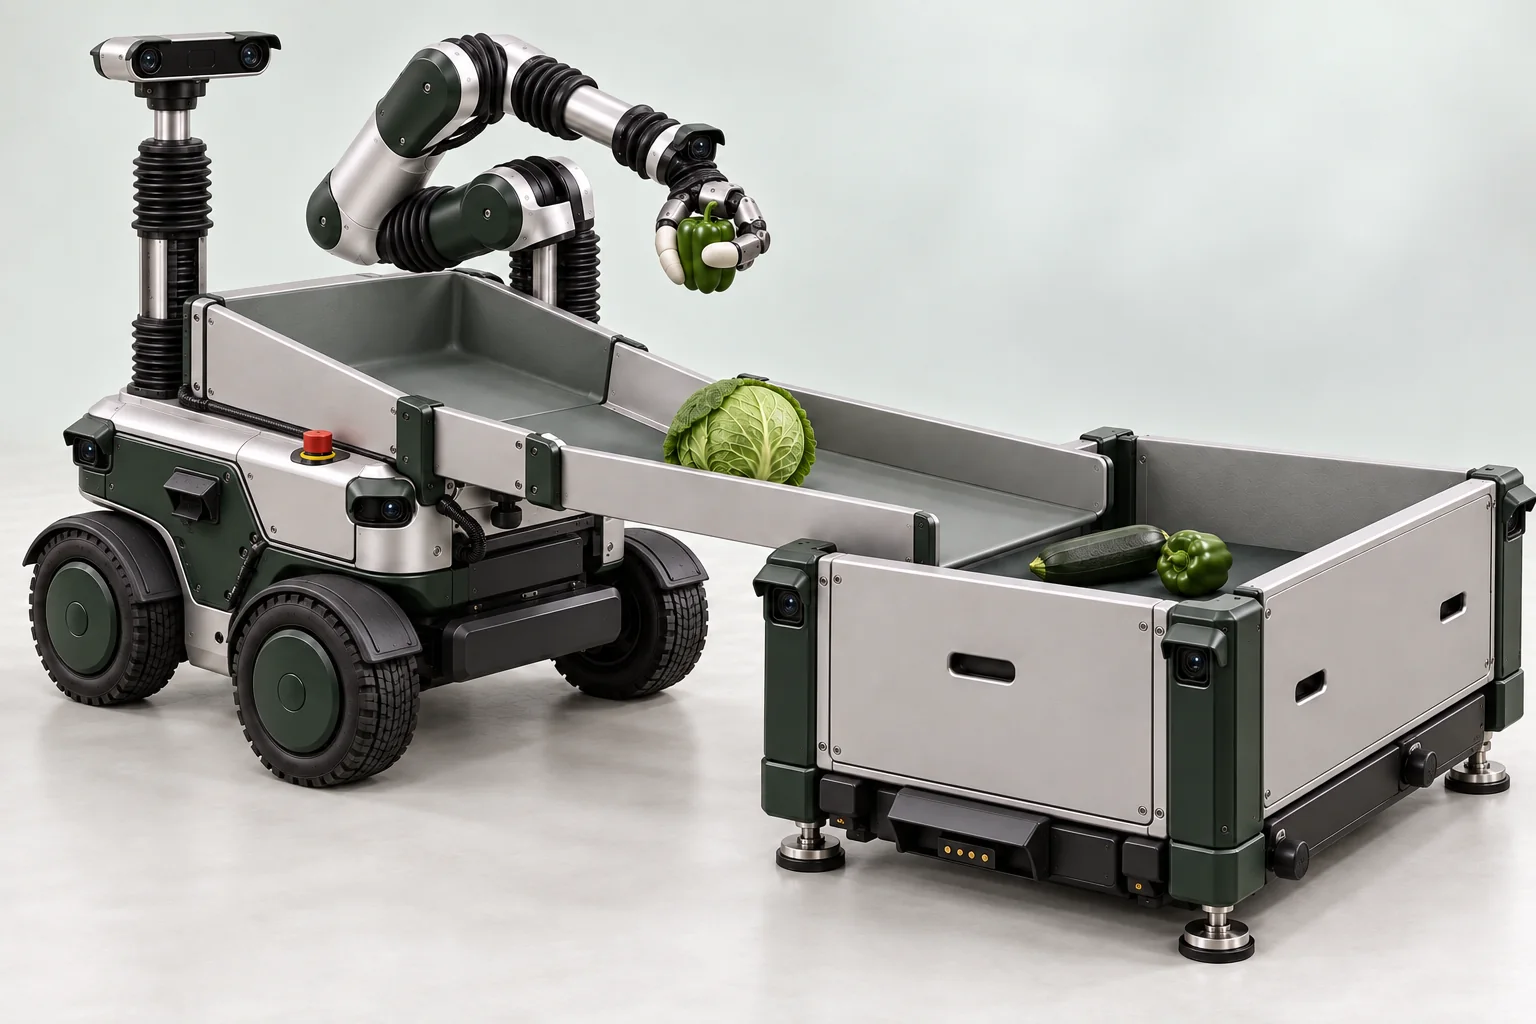
The proposed belt would move vegetables from the onboard tray into the larger receiving bin. A continuous, grippy surface would carry them down a slight incline under power.
Electric actuation · Form study
A robot. A harvest station. A solar dock. One connected system in development.
How it works
With the robot stopped beside the bin, the belt would extend over its opening. The moving surface would carry the produce even at a shallow angle.
The robot’s basket would stay in place. Only the vegetables would pass into the receiving bin, leaving the hand free for the next pick.
What we need to test
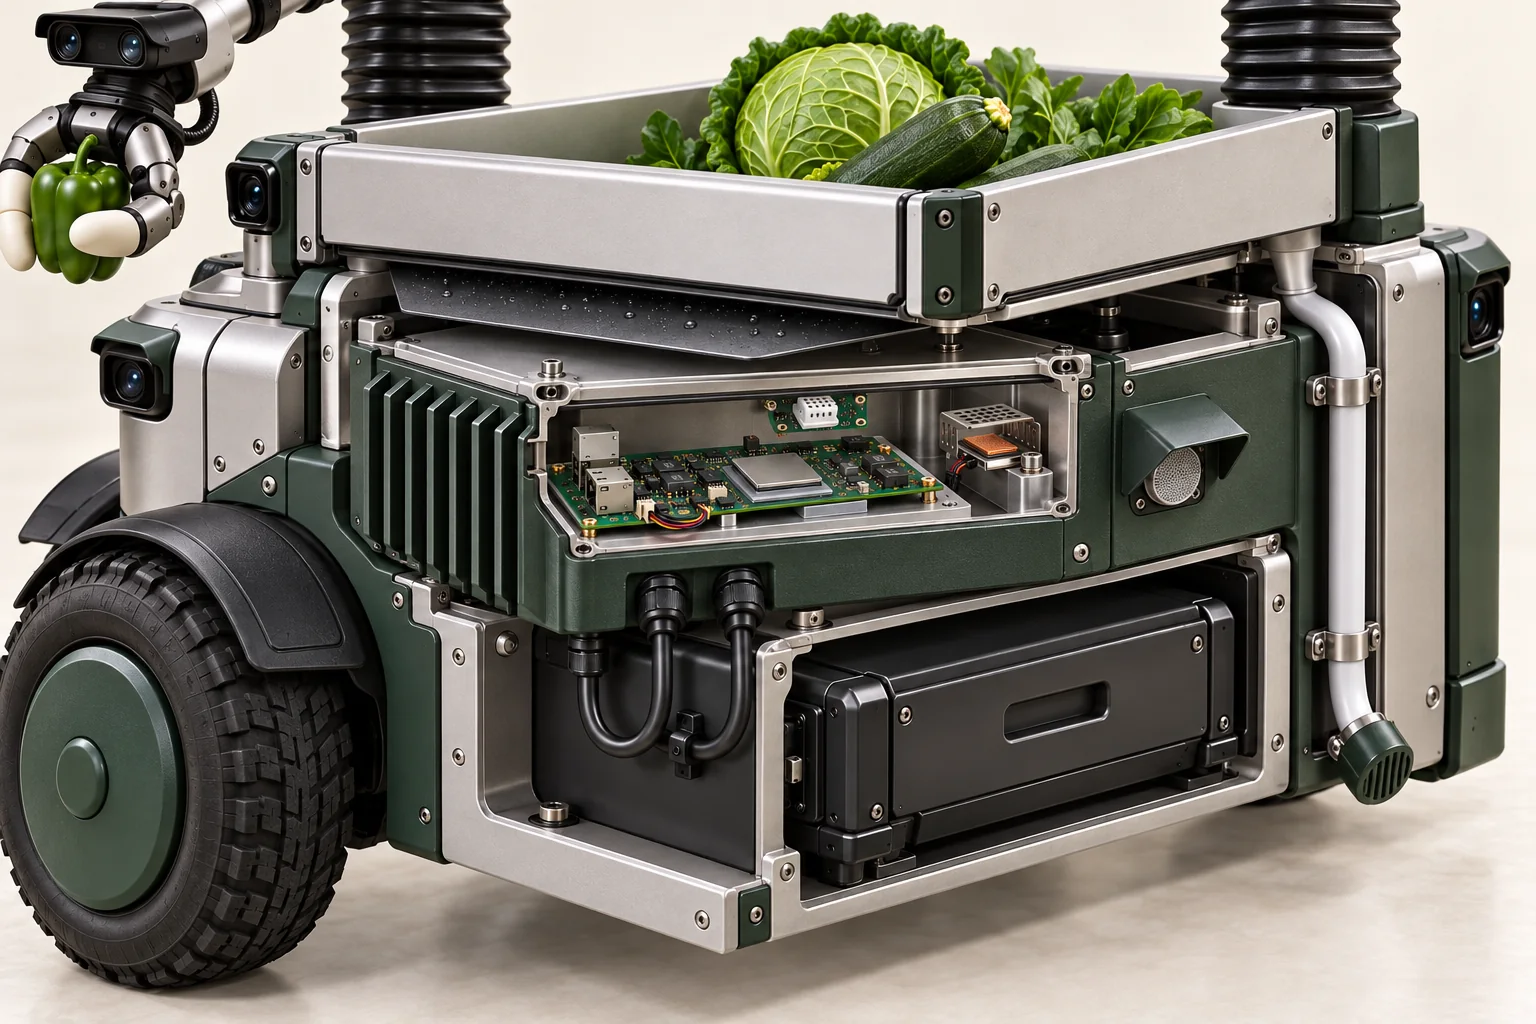
- Try wet and dry crops of different shapes. Measure whether they slip, jam or bruise as belt speed and drop height change.
- Check access for cleaning and test how the drive stops if an item catches during transfer.